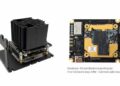




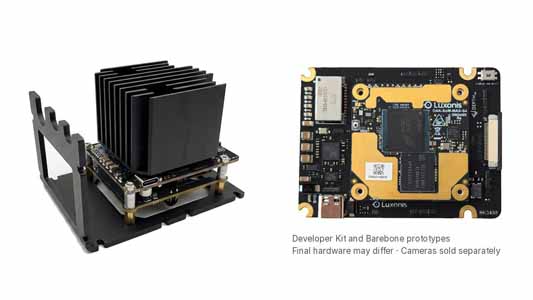

DENVER–Luxonis, the company behind the OAK camera and DepthAI software, has released OAK 4 FFC, the first OAK Modular device built on OAK 4: a board-level vision computer for humanoids, drones, and other machines that a standard camera does not fit. Builders connect up to five Luxonis camera modules in the positions and spacing their design calls for. The board then handles synchronization, calibration, stereo depth, and AI on its 6-core RVC4 processor, with 52 total TOPS of compute.
Today, a custom multi-camera rig usually means sourcing compute, a carrier board, cameras, and drivers from different vendors. Teams then write their own synchronization and calibration tools before the real application work starts. With OAK 4 FFC, the camera modules, compute, firmware, DepthAI SDK, and OAK Viewer come from one platform and are built to work together.
Five cameras, placed by the builder
Teams choose from nine modules across three sensors: the 48 MP IMX586 color sensor, and 1 MP OV9282 and 5 MP OG05 global shutter sensors, in standard and wide fields of view. Builders set their own stereo baselines and viewpoints. A humanoid head, for example, can carry a forward stereo pair at human eye spacing plus side and rear cameras, all on a single board. Thermal, Time-of-Flight (ToF) and additional global shutter modules are coming soon, and teams can contact Luxonis at sales@luxonis.com for details or prototype access.
Calibrated without a calibration board
Each module ships with factory-calibrated intrinsics stored on the module. Users enter camera positions in OAK Viewer, and Luxonis Dynamic Calibration then refines the alignment of cameras with overlapping views using ordinary scene texture. That calibration turns a custom layout into usable output: stereo pairs at whatever baseline the builder chooses for depth, or panoramic and bird’s-eye views stitched together from overlapping cameras.
Two roles on a robot
On a stationary system or a simpler robot, OAK 4 FFC can be the main computer. It runs the Linux-based Luxonis OS, so the camera pipeline, AI models, and application logic all live on the board. On a more complex robot, it becomes the dedicated perception system. It processes everything the cameras see on the device and sends results such as depth, detections, and tracked objects to the robot’s main computer. That computer keeps its capacity for planning, manipulation, and large AI models. For either role, the board provides 2.5 Gigabit Ethernet, PoE+ through the PoE module included in the Developer Kit, 6-32 V DC input, USB-C, CAN, and hardware frame sync.
“The machines our customers are building, from humanoids and drones to surgical and mobile robots, don’t have room for a camera designed for someone else’s machine. They kept asking for the same thing: let us choose the sensors and where they go, and you handle the hard parts underneath. With OAK Modular now on OAK 4, a team can design its vision system around its robot, instead of its robot around a camera.” – Bradley Dillon, CEO of Luxonis
From the bench to the machine
The Developer Kit and the 36 g Barebone share the same vision core and run the same application. The Developer Kit adds a heatsink, bracket, PoE+ module, and connectors so it works on a desk. The Barebone goes into the customer’s own enclosure, with their own cooling and power. Luxonis is also releasing the OAK 4 FFC reference design as open source, so teams can build their own carrier board around the OAK 4 SoM.
Pricing and Availability
Orders open today for the OAK 4 FFC Developer Kit at $849 and the OAK 4 FFC Barebone at $729. Both prices include a temporary $200 surcharge for memory and storage. Camera modules are sold separately starting at $39.99. Developer Kit orders begin shipping in November and Barebone deliveries are scheduled for Q1 2027. To learn more, visit www.luxonis.com/oak4-ffc.